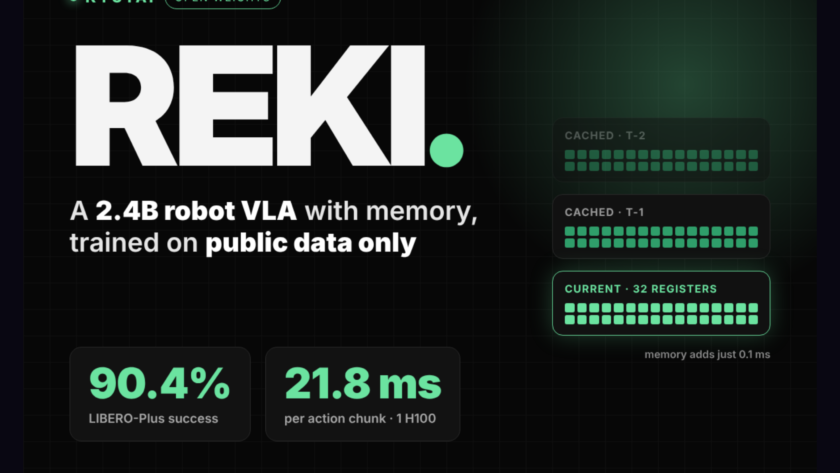
Kyutai, with Inria and École des Ponts, has released REKI, a 2.4B vision-language-action model (VLA) for robot manipulation. The REKI vision-language-action model is pretrained only on public data. It also carries a cheap memory of its recent past. On three out-of-distribution benchmarks, only models about twice its size beat it. All weights are live on…
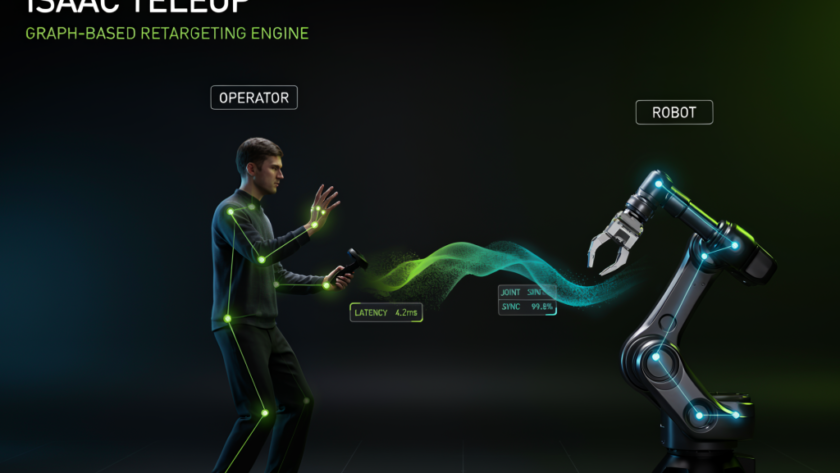
In this tutorial, we work through the retargeting engine at the core of NVIDIA IsaacTeleop, the framework that turns XR hand tracking and motion-controller input into commands for simulated and real robots. Rather than plugging in a headset, we build every input ourselves in NumPy, so each step runs on a plain Colab CPU and…
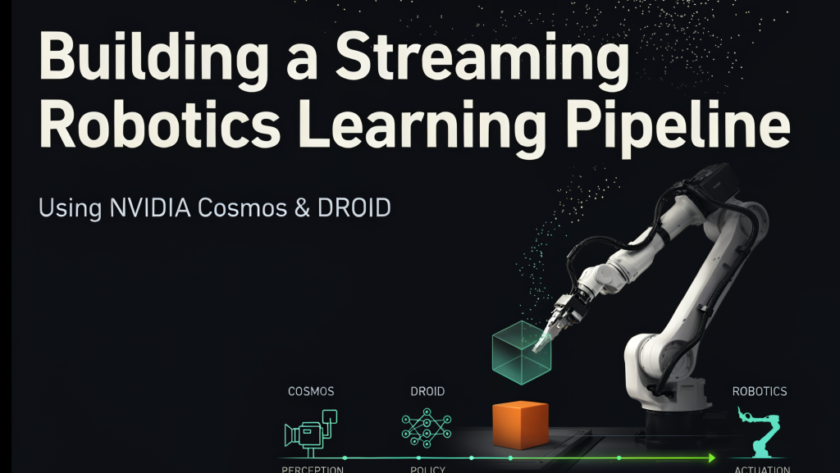
In this tutorial, we design an end-to-end streaming robotics learning pipeline around the NVIDIA Cosmos3-DROID dataset without downloading its 707 GB repository locally. We first introspect the LeRobotDataset v3.0 structure and construct a metadata graph from info.json, task metadata, episode tables, and dataset statistics, then use HTTP byte-range access with PyArrow to selectively read Parquet…
Video world models can render convincing clips that still break physics. Butter spreads like paint. Balls pass through walls. A team from NVIDIA, MIT and the University of Oxford argues the fix can come from language itself, not from extra visual, latent or numerical signals.
Their framework, Physis-Lang, treats physical language as a shared, optimizable…
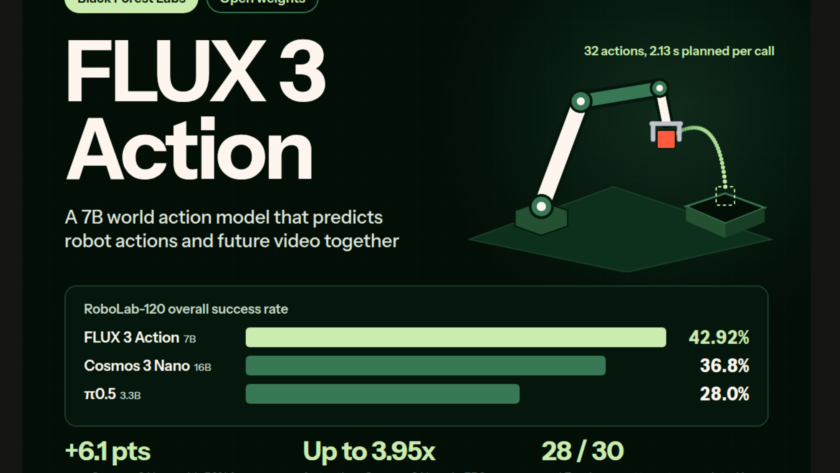
Black Forest Labs Releases FLUX 3 Action: A 7B Open-Weights World Action Model That Tops RoboLab-120
Black Forest Labs (BFL), the lab behind the FLUX image models, has released FLUX 3 Action. It is a 7B open-weights World Action Model (WAM) for robot control. The model reads camera frames, robot state and a text instruction. It then predicts future video frames and the next chunk of actions together. On the RoboLab-120…
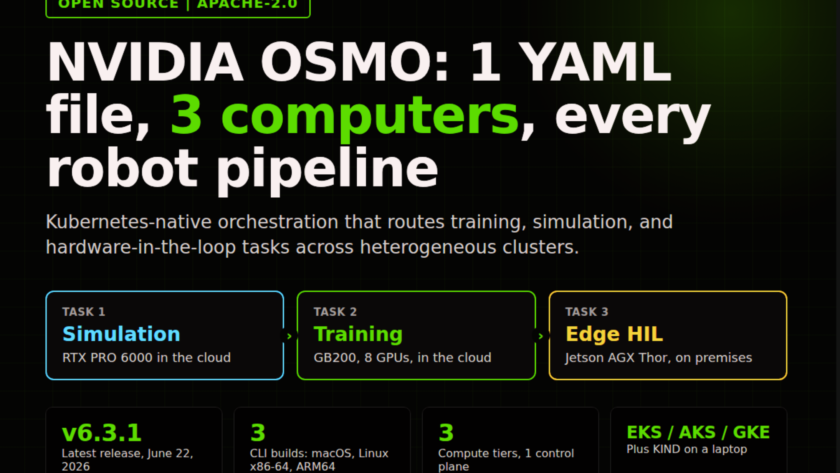
Robot developers do not have one compute problem. They have 3. A policy is trained on GB200 or H100 clusters, tested in Isaac Sim on RTX GPUs, then validated on a Jetson mounted inside a real robot. Each tier has its own cluster, its own scheduler, and its own glue scripts. NVIDIA OSMO is NVIDIA’s…
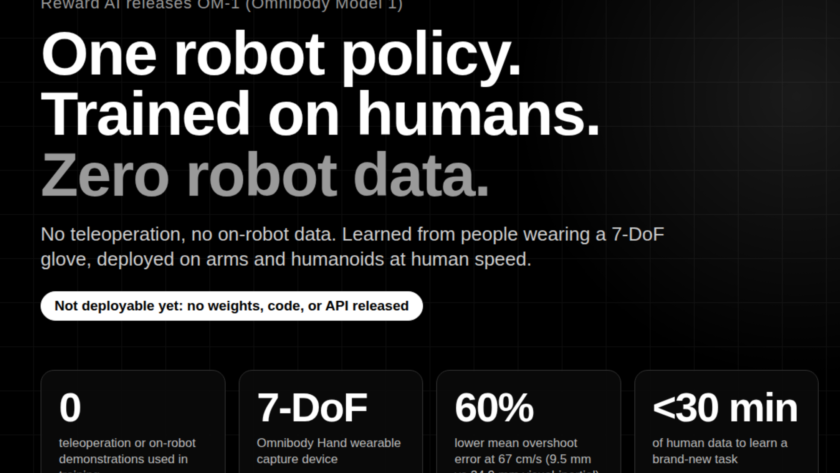
Reward AI, a robotics startup whose team’s prior work includes DexCap, HumanPlus, and ALOHA, has released OM-1, short for Omnibody Model 1. OM-1 is a general-purpose manipulation policy that learns from humans wearing a sensorized glove, then runs on industrial arms and humanoids at human speed. The key findings that stands out: no teleoperation data…
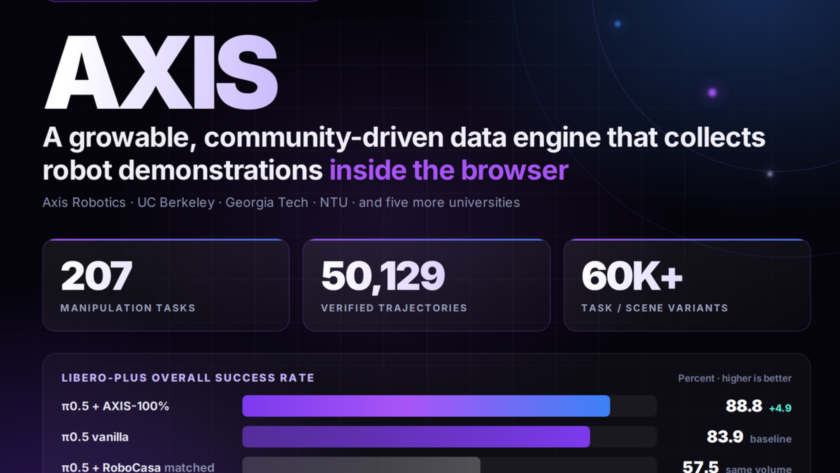
Robot manipulation datasets have grown far slower than the models trained on them, mostly because collection stays closed and centralized. Expert operators gather demonstrations on lab hardware, process them offline, and ship a fixed benchmark that never grows again. A research team from Axis Robotics, UC Berkeley, Georgia Tech, NTU… is proposing a different shape…
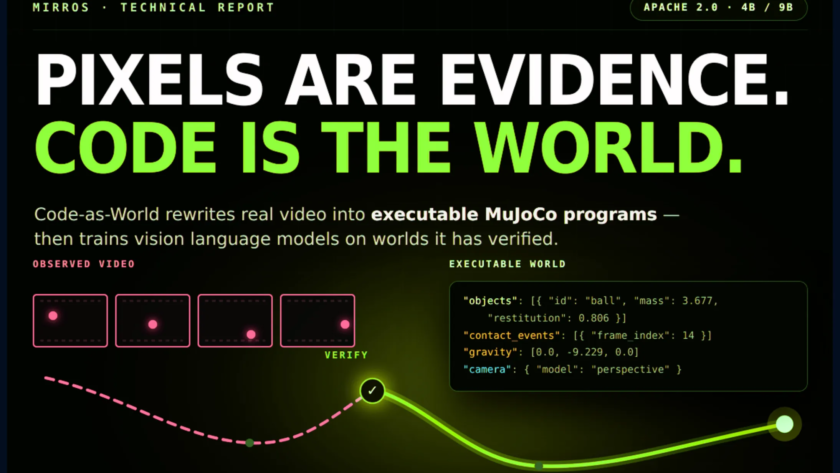
MirroS released Code-as-World: a paradigm that represents physical worlds through executable world representations. The argument is narrow and testable: pixels are evidence of a physical scene, not its ontology. A video model can predict plausible frames without ever representing mass, contact, or gravity. So instead of pixels, latents, or captions, Code-as-World represents a scene as…
Hugging Face Unveils Microduck: A $399 Open-Source 25 cm Biped You Train with Reinforcement Learning
Most robotics launches ask you to trust a demo video. Pollen Robotics, the Bordeaux robotics team at Hugging Face, is instead shipping the training loop. This week it opened pre-orders for Microduck, a 25 cm bipedal robot in which every movement — walking, sitting, kicking, roller-skating, standing back up after a fall — is a…